 Haoru UWB
Project requirements
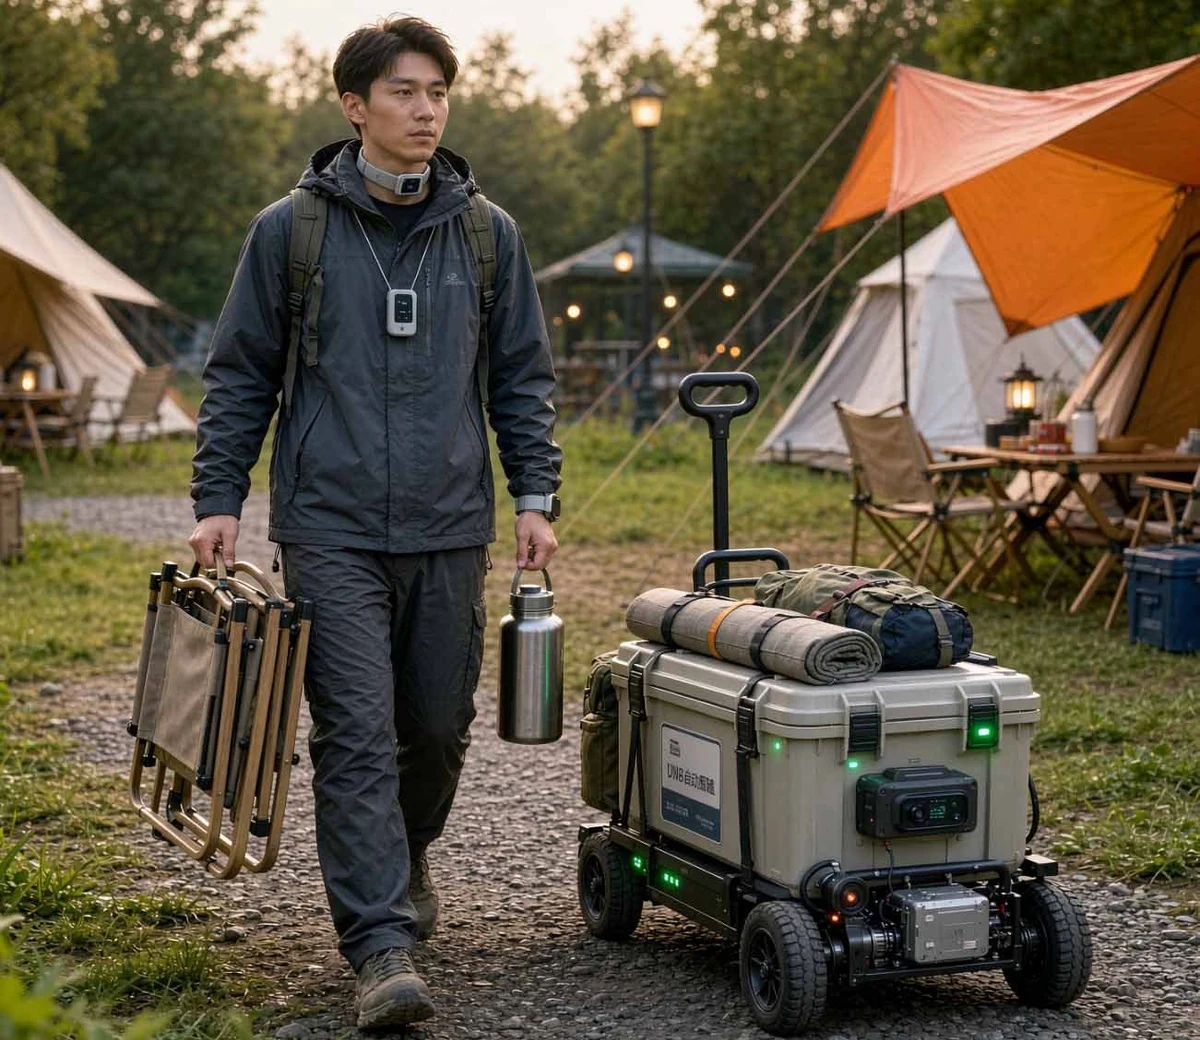
Manual camping carts require continuous pushing and can be difficult on grass or sand, particularly while carrying items or supervising children. A conversion must also address parking on slopes, obstacles and the intended terrain.
Solution
The described conversion integrates UWB range/angle processing, control, drive and obstacle sensing into an existing cart. A carried tag supplies the relative target position for configurable 360° following and a 1–15m following distance. The planned vehicle behavior includes obstacle handling, parking on abnormal conditions and remote-control operation, subject to the chassis and controller configuration.
EfficiencyThe case description reports approximately 50% less camp setup/material-transfer time and 40% fewer retrieval trips, allowing some two-person tasks to be performed by one person.
User ExperienceReported physical effort decreased by approximately 70%, particularly on slopes and longer routes, with following stability above 95% in the described evaluation.
SafetyThe case reports no slope roll-away events during its evaluation and obstacle response below 0.3 seconds. UWB target tracking does not require lighting, but complete vehicle performance depends on the sensors, surface and environment.