 Haoru UWB
Project requirements
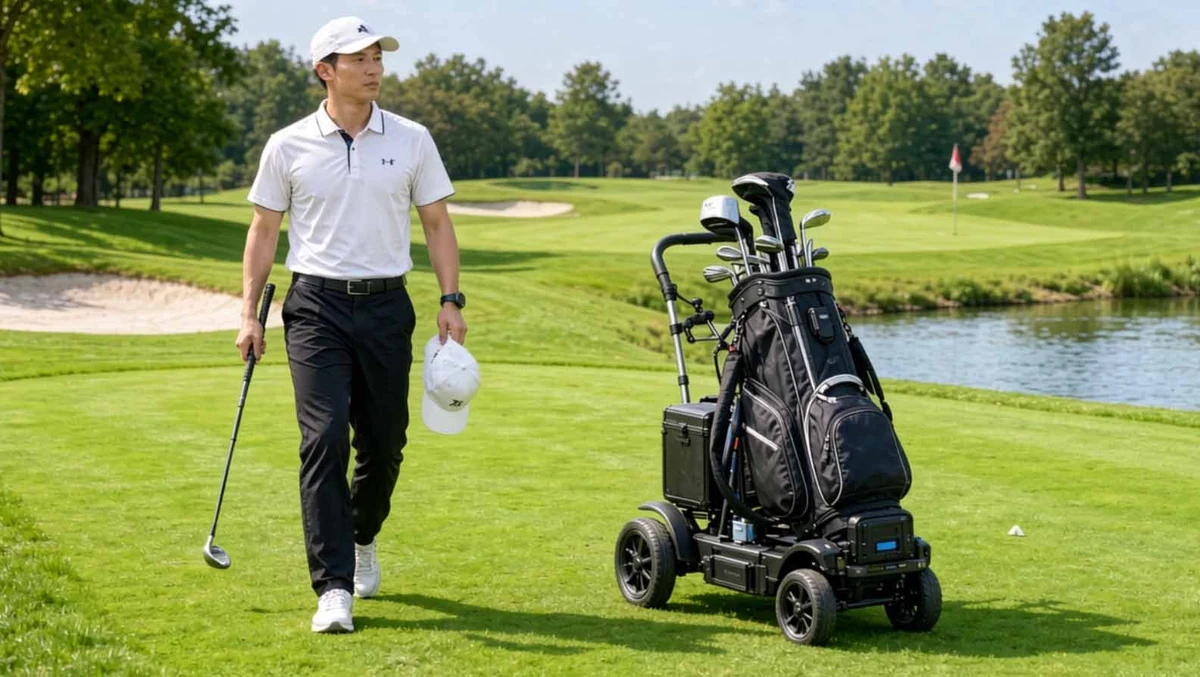
Driving or pushing a conventional cart interrupts play and increases effort, especially with multiple clubs and equipment. Slopes and sand also complicate vehicle control and parking.
Solution
The described conversion combines UWB PDoA/AoA, drive, control and obstacle sensing. The cart follows a carried tag at an adjustable 1–15m distance, with obstacle handling, abnormal-condition parking and optional remote control according to the supported platform.
EfficiencyThe case reports approximately 20% less time for an eighteen-hole round and 50% less cart-dispatch time.
User ExperienceReported player effort decreased by approximately 40%, with following stability above 95% in the described slope and sand evaluations.
SafetyThe case reports no slope roll-away events during its evaluation, obstacle response below 0.3 seconds and parking while the player stops.