 Haoru UWB
Project requirements
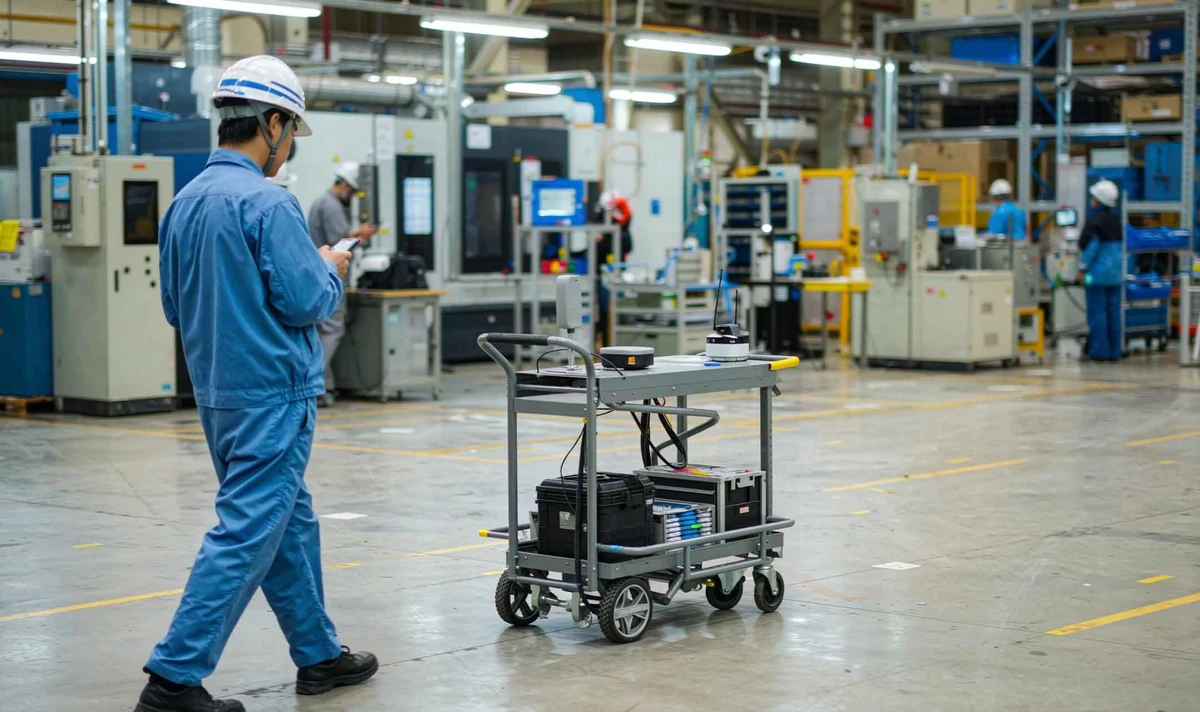
Workers carry heavy tools and instruments across workshops and warehouses. Manual carts occupy their hands and increase physical effort. A following conversion must track a moving worker, stop when needed, steer smoothly and handle dense equipment, narrow aisles and temporary obstacles.
Solution
The described project combines a UWB following kit with vehicle control, drive and sensing components in an integrated platform.
A carried tag and vehicle module measure relative range and direction for following and separation control.
The controller uses wheel feedback and suitable motion sensors to adjust wheel speeds for turns, acceleration, deceleration and stopping.
The drive uses high-torque motors and replaceable lithium batteries selected for the required load and working duration.
The applicable sensing configuration combines ultrasound, infrared and LiDAR for detecting obstacles, reducing speed or bypassing and triggering emergency braking as designed.
The control architecture coordinates sensing, decisions, motion and stopping to support hands-free tool transport.
The case description reports the following results:
Work EfficiencyPreparation and travel time per task reportedly decreased by approximately 40%, and tool delivery to a workstation by approximately 50%.
Labor RequirementsReported physical effort during transport decreased by approximately 60%, with approximately 30% less equivalent transport-assistance labor in the described workshop.
Operating SafetyThe case description reports over 99% obstacle-handling success, no collisions during the reported operation and emergency-braking response within 0.3 seconds. These figures require validation for each vehicle application.