 Haoru UWB
Solution
Summary
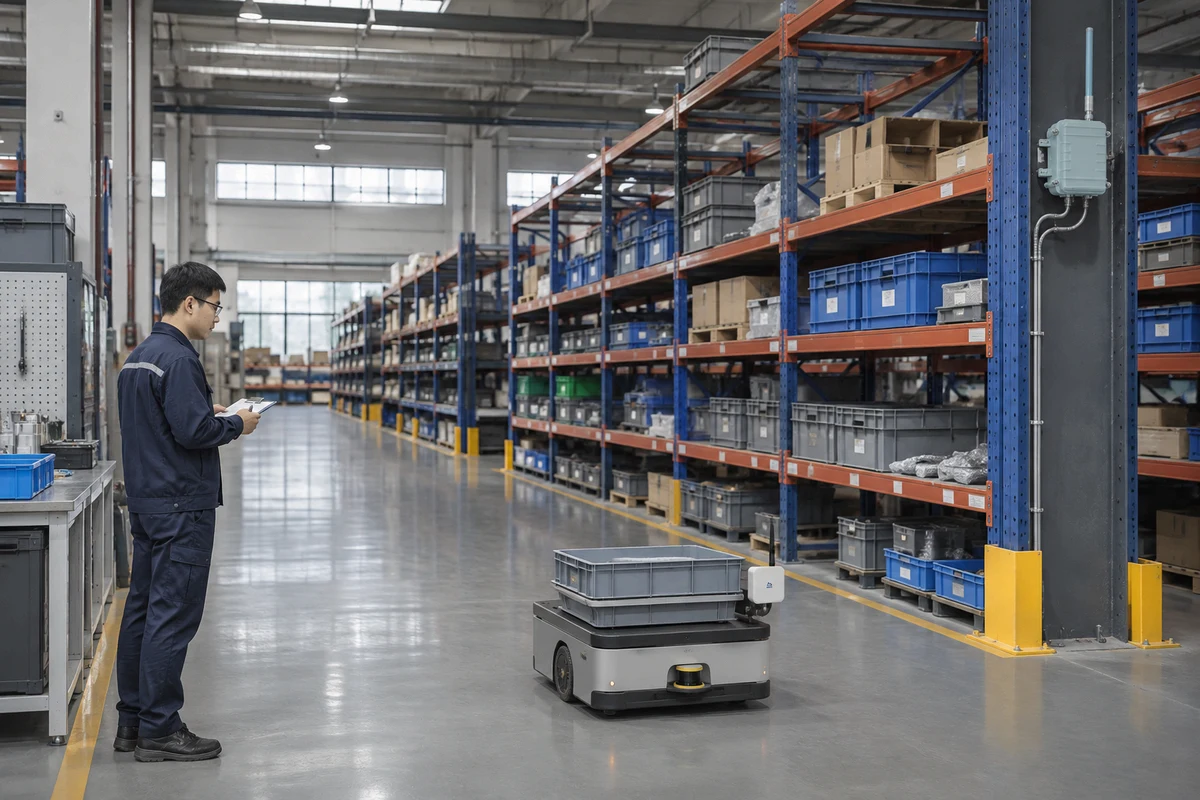
Haoru Technology provides ultra-wideband (UWB) assisted positioning for autonomous mobile robots operating among repetitive racks, long corridors and changing layouts. Tag positions are transformed into the customer's navigation map and supplied as timed observations to the existing localization system. Fusing these observations with the robot's LiDAR, vision or odometry data helps verify its operating area, recover its position and maintain task continuity.
Application Background
An autonomous mobile robot, or AMR, must continuously determine its position within a map before its navigation system plans a route and executes a transport task. Similar rack rows, repetitive corridors and changing material arrangements can make the robot's existing localization inputs inconsistent.
Recovery often requires a person to inspect the robot, set its starting position again and resume the task. The customer wants to retain its chassis, navigation software and obstacle handling while adding an independent position reference for recovery in these specific areas.
Project Challenges
1. UWB site coordinates differ from robot map coordinates. Without a common origin, orientation and installation offset, the new positions cannot be used directly in navigation calculations.
2. Data sources update at different times. If the robot treats an older observation as its current position while moving, the resulting estimate can be misleading.
3. Metal racks and stored goods affect ranging. The fusion system must assess continuity and validity rather than sending every observation directly into motion control.
Haoru Technology Solution
Haoru Technology deploys UWB base stations in areas requiring additional positioning and installs a tag on the robot, supplying ranging, position calculation and data output. The tag is mounted away from major metal obstructions, and its offset from the robot reference point is recorded.
We work with the customer's navigation team to calibrate the transformation between site coordinates and the navigation map. After coordinate transformation and mounting offset correction, UWB positions enter the customer's localization fusion program as external observations. The existing navigation system continues to handle route planning, speed control and obstacles.
Project integration logic checks observations against timestamps, trajectory continuity and robot motion. When data are missing or clearly inconsistent, the fusion program reduces their weight or excludes them temporarily and records the diagnostic information. After the robot passes through a changed area, engineers can compare position sources to investigate recovery problems.
How It Works
1. Establish the reference: calibrate base station coordinates, measure the tag's offset from the robot reference point and establish the mapping to navigation coordinates.
2. Acquire observations: the UWB system calculates tag positions and sends coordinates and timing information to the customer's data interface.
3. Fuse the sources: the customer localization program aligns UWB, odometry and existing sensor data in time, then updates the position estimate using validity checks.
4. Resume tasks: navigation uses the fused position to continue planning and driving, while position changes and exceptions remain available for replay.
Solution Advantages
1. The customer retains its navigation architecture while UWB supplies an independent position reference, limiting changes to the overall robot system.
2. A common coordinate and time framework makes site positions and robot motion easier to compare during recovery and troubleshooting.
3. Deployment and tuning focus on the relevant areas, providing an interpretable response to repetitive structures and layout changes.
Final Results
Manual interventions during localization recovery decreased by 50%. The additional position reference helps establish the robot's operating area and reduces manual position resets at the vehicle.
Localization integration hours after layout changes decreased by 40%. A fixed site reference and trajectory records help engineers check map and position relationships more quickly.
Time spent reviewing position exceptions decreased by 60%. Synchronized replay of different position sources reduces separate log searches and manual record alignment.