 Haoru UWB
UWB Positioning
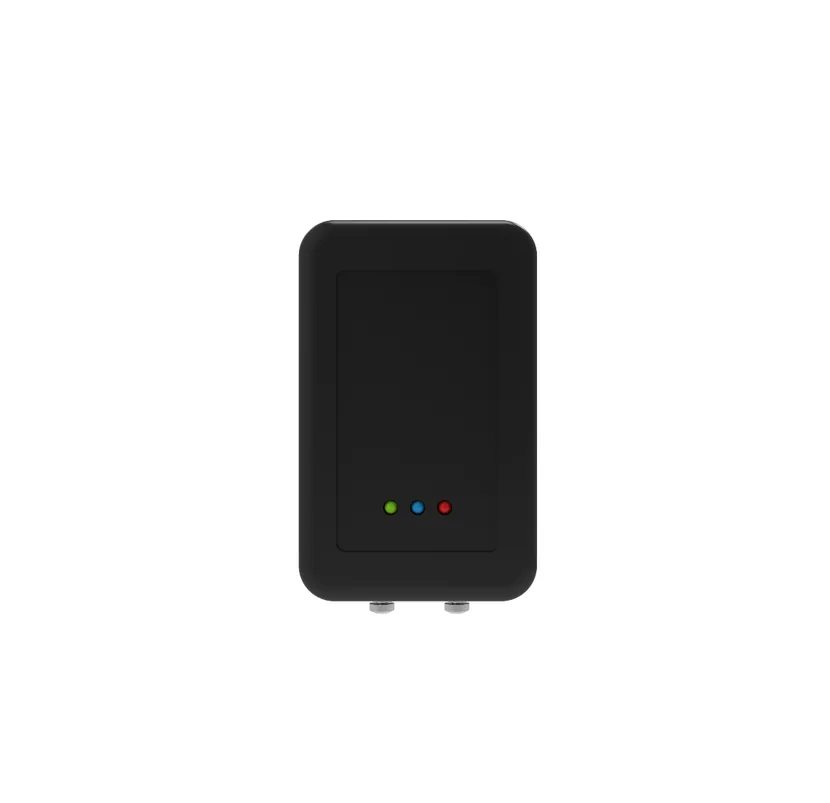
ULM3-PDOA UWB Ranging and Angle Measurement Module
DW3220 · PDoA / AoA
A DW3220-based dual-antenna PDoA anchor for ranging and angle measurement, suitable for supported single-anchor positioning and following configurations.
Specifications
Specifications
Key Specifications
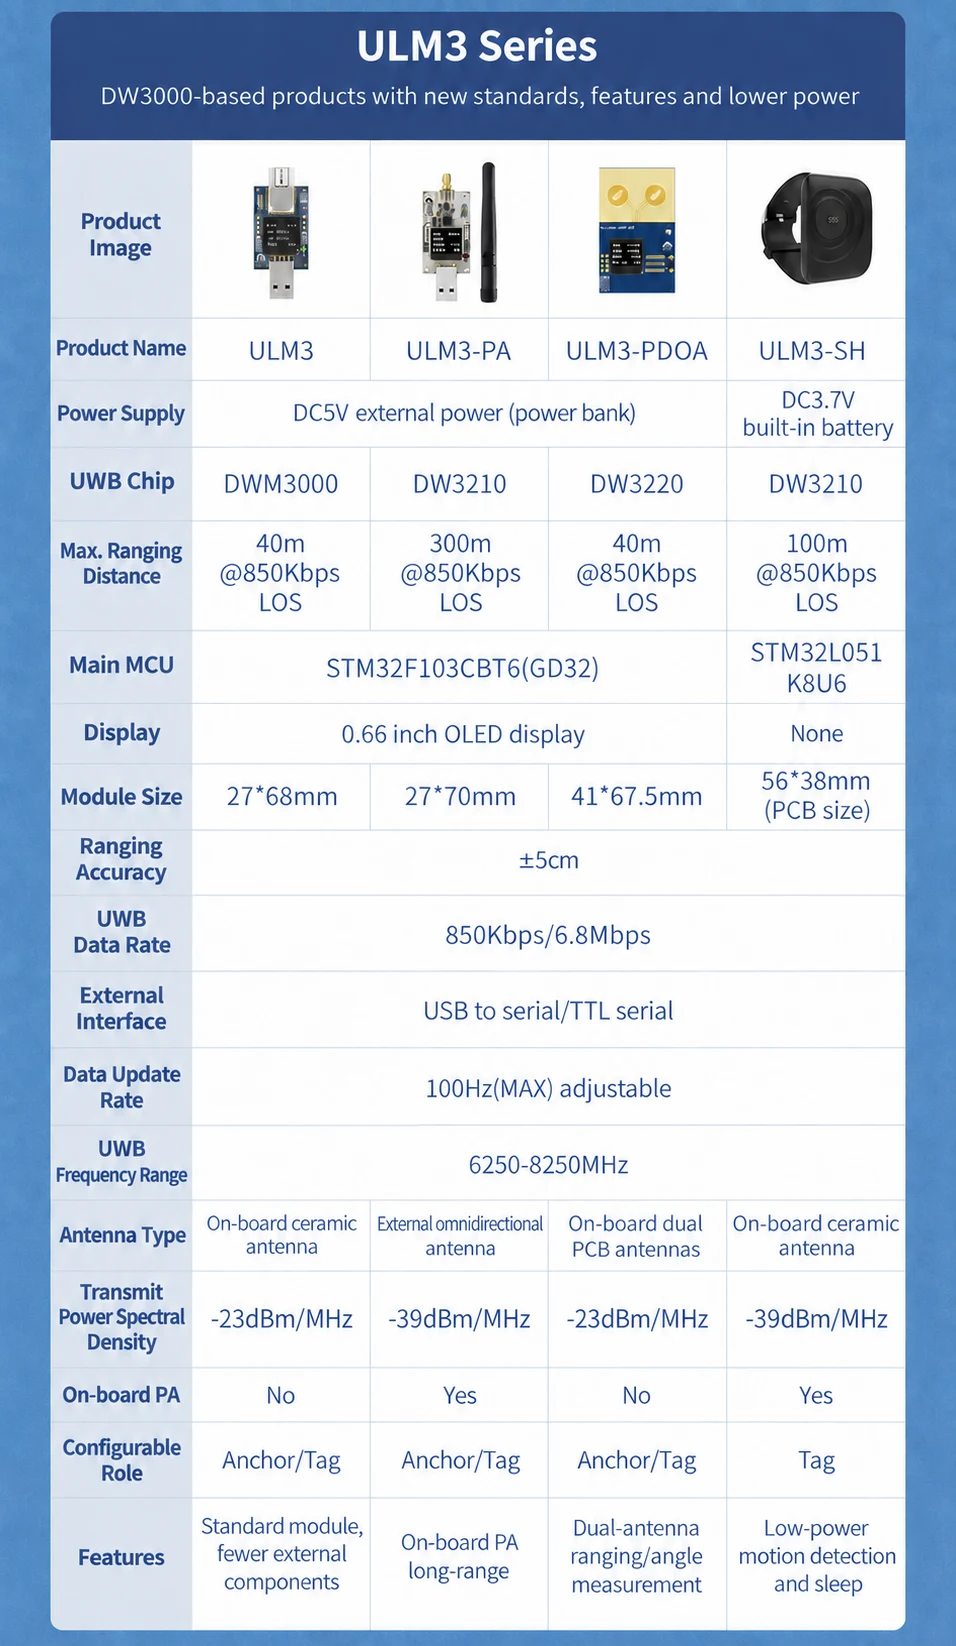
- Maximum Ranging Distance
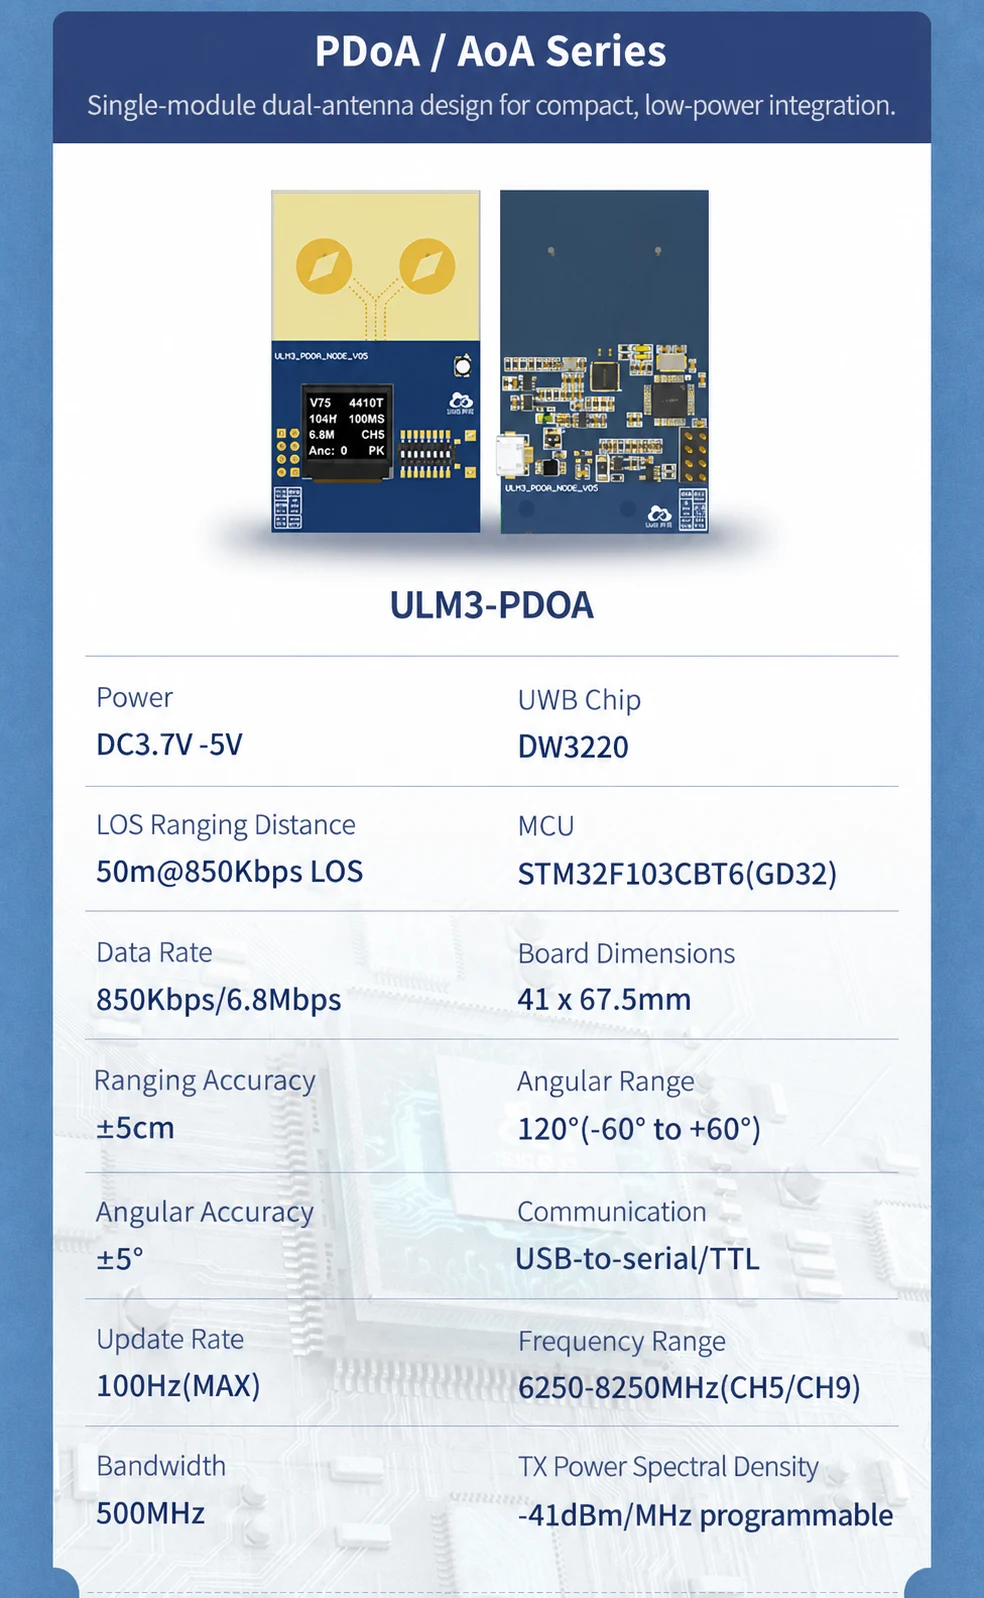
- 40m @ 850Kbps (open-area LOS)
- Ranging Accuracy
- ±5cm
- Angular Field of View
- -60°~+60°
- Angular Accuracy
- ±5°
- Chipset
- DW3220
- Module Dimensions
- 41*67.5mm
- Configurable Role
- Anchor / Tag
- Additional Features
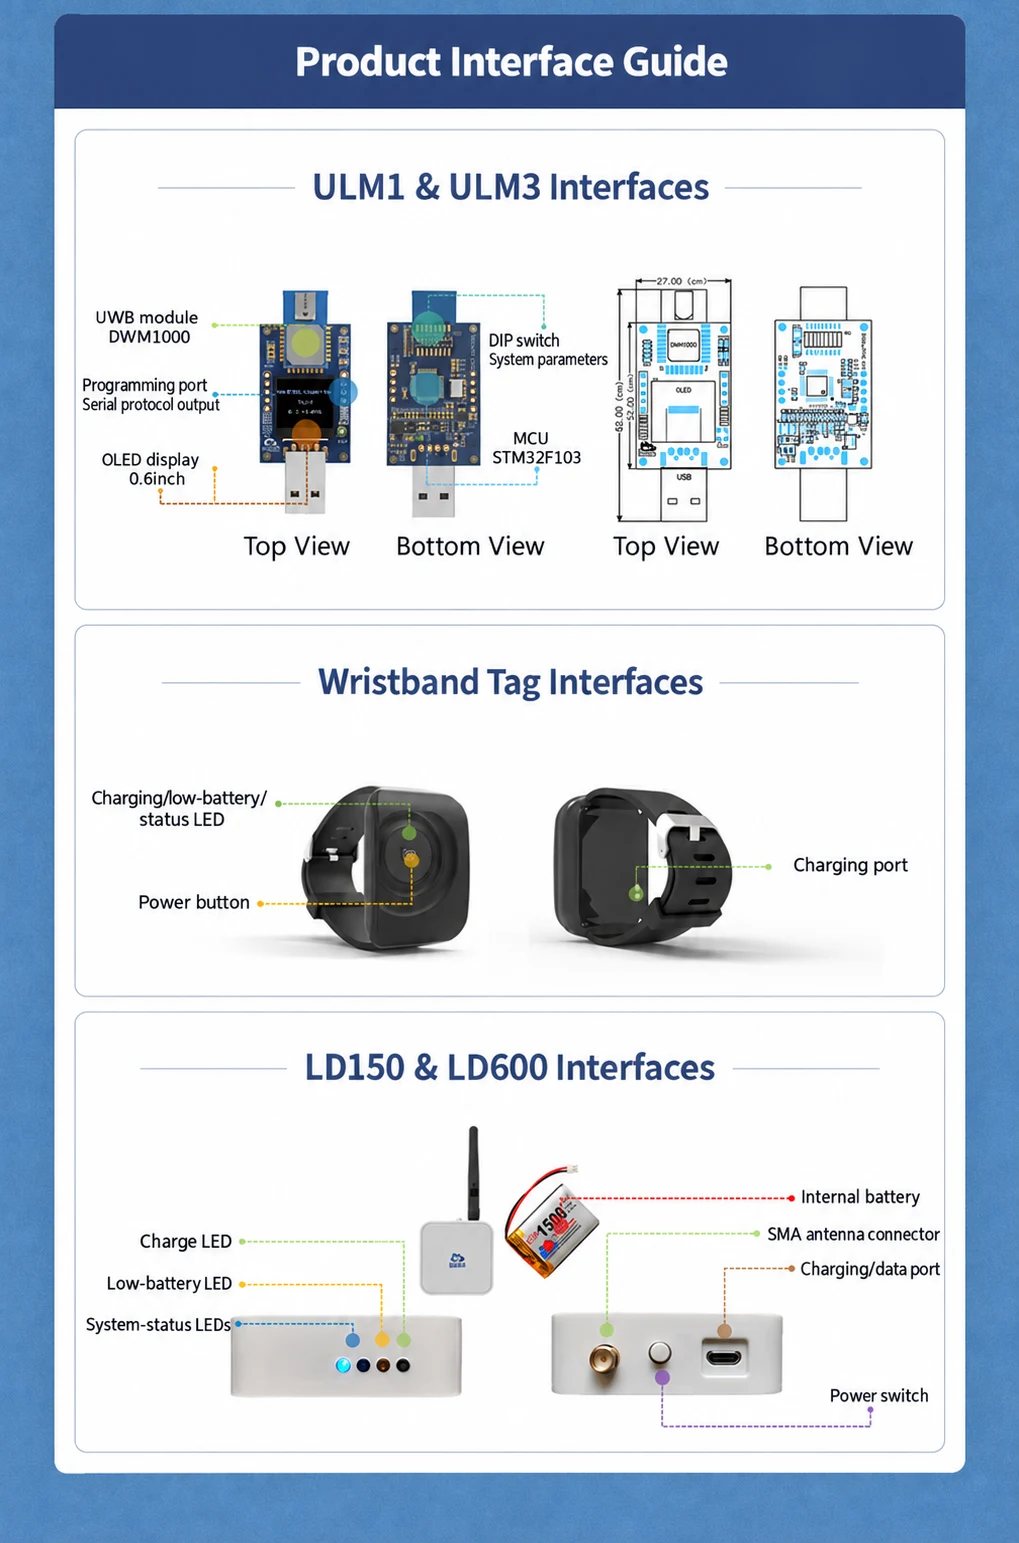
- 0.66-inch OLED display; USB-to-UART / TTL UART; two onboard PCB antennas for ranging and angle measurement
Overview
Product overview
Range and angle measurements for a host controller
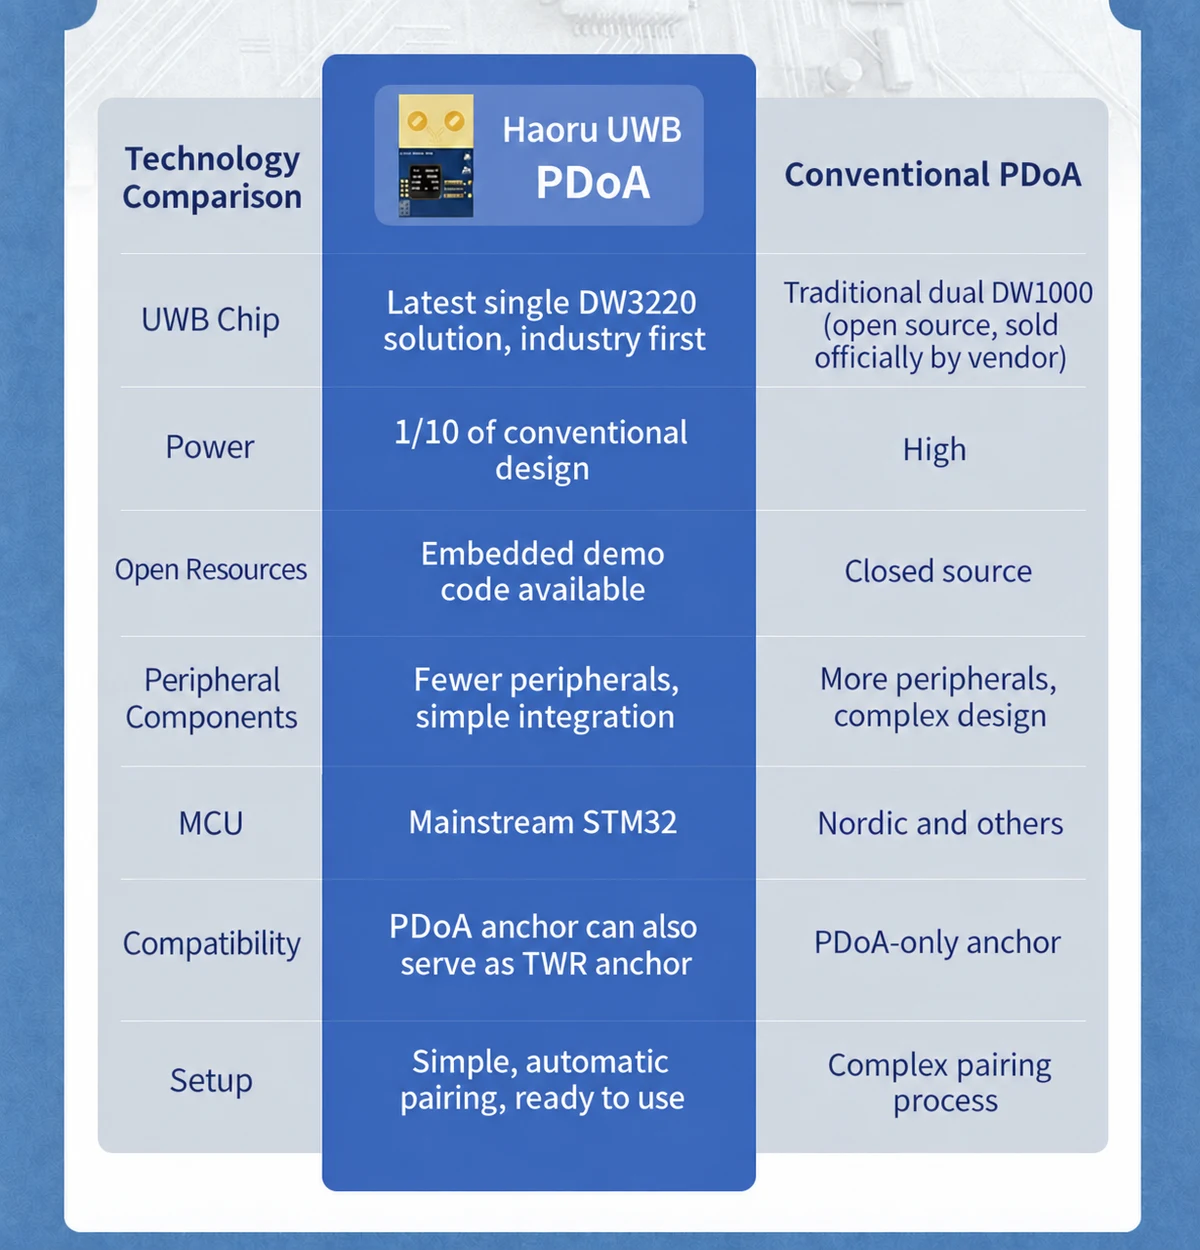
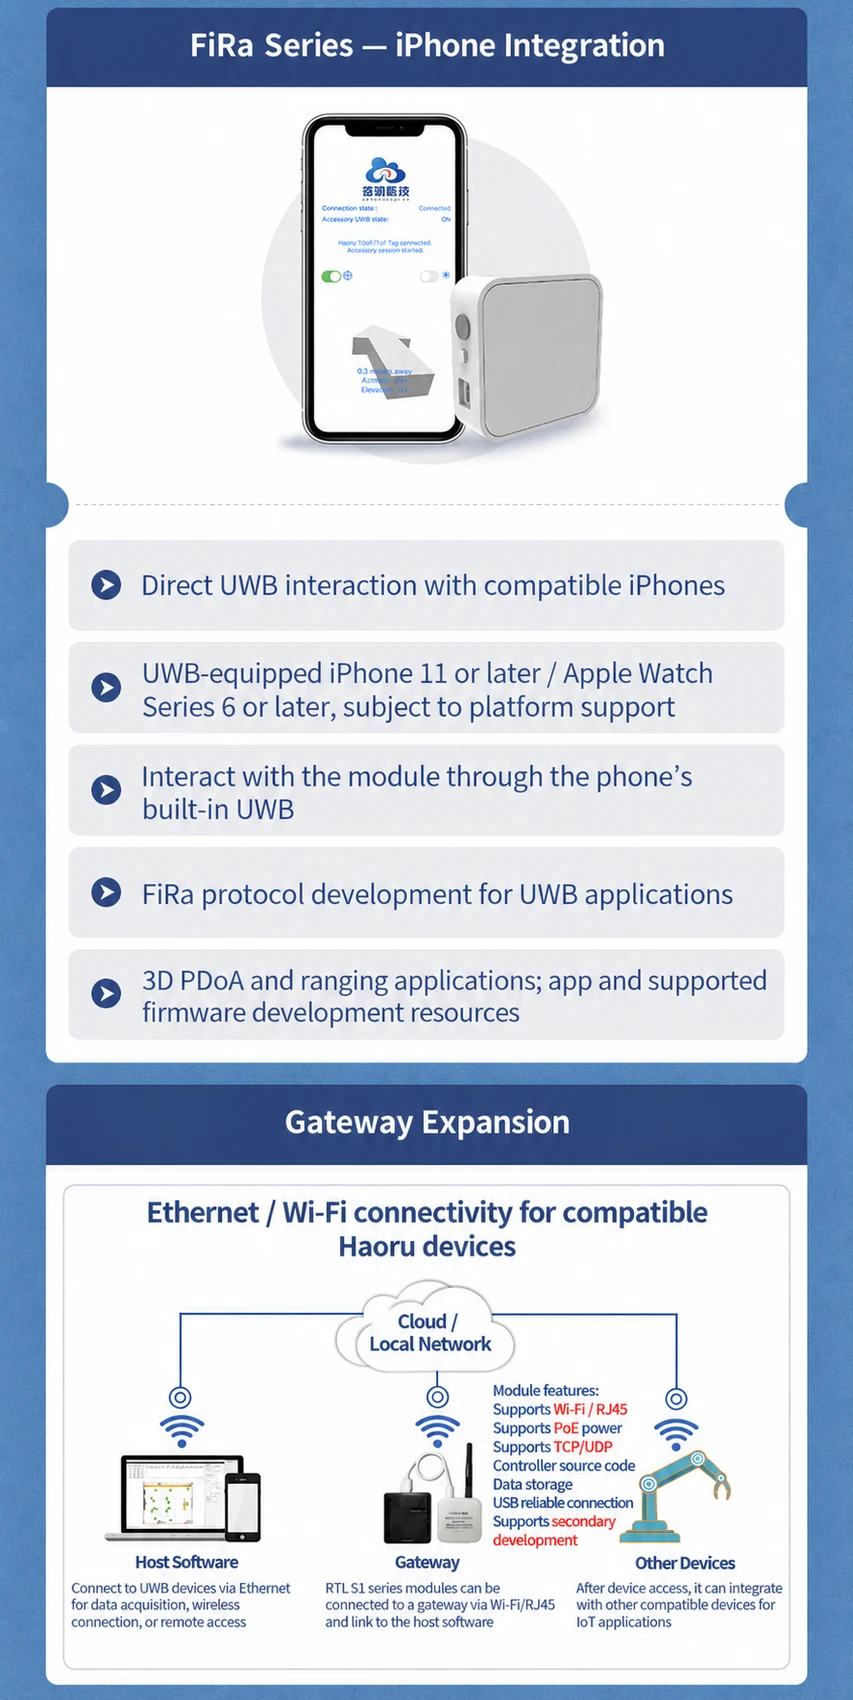
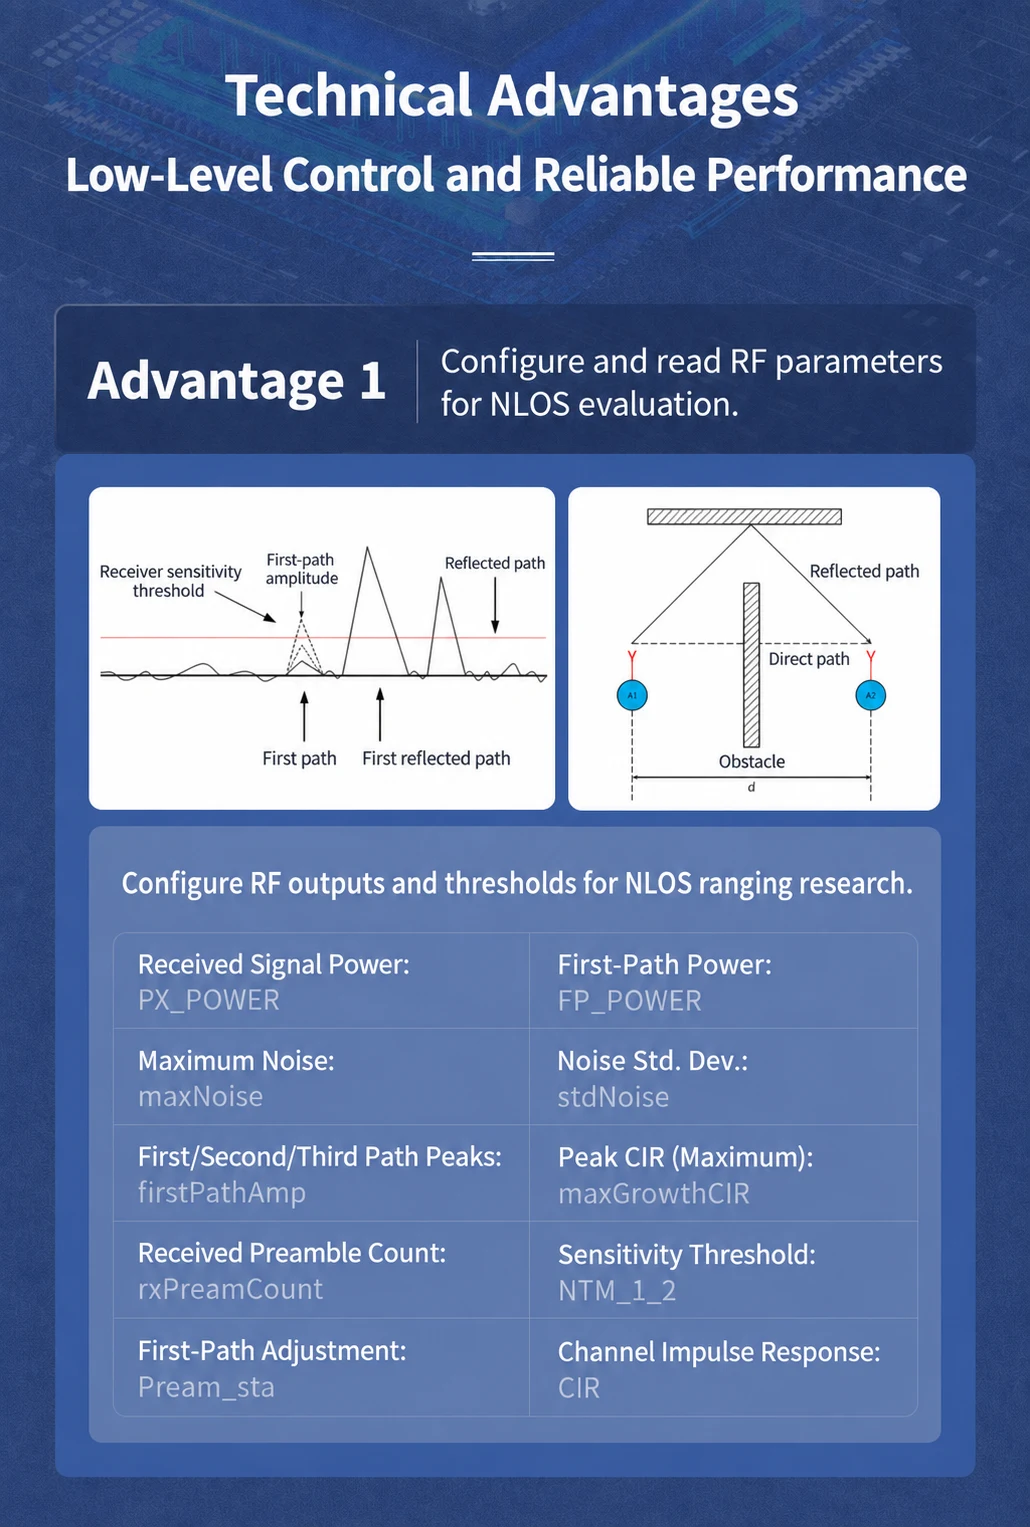
ULM3-PDOA is a DW3220-based dual-antenna anchor for supported ranging and angle-of-arrival applications. The manual describes pairing it with compatible ULM3-family tags and sending measurements over USB-to-serial or TTL UART. It is a measurement subsystem; a following robot also needs its own motion controller or an appropriate complete kit.
Coverage, mounting and data output
The referenced manual specifies a forward angular range of -60° to +60° and recommends a tag distance greater than 1 m. Keep the antenna face oriented toward the working area and test with representative obstructions. Do not interpret one module's field of view as 360° vehicle coverage.
The documented MP serial format uses 115200 baud, 8 data bits, no parity and 1 stop bit. It includes target identity, coordinates, range and angle information. Coordinates and distance fields use centimetres and angle fields use degrees in this format; confirm field order and the packet variant for the delivered firmware. PDoA and AoA values are different fields and should not be used interchangeably.
The manual describes a 12 ms tag slot at 850 kbps and a four-tag 48 ms configuration. Host processing and the selected settings affect application timing. Confirm hardware revision, enclosure dimensions, firmware and calibration requirements before mechanical integration; the full and Lite versions have separate documents.
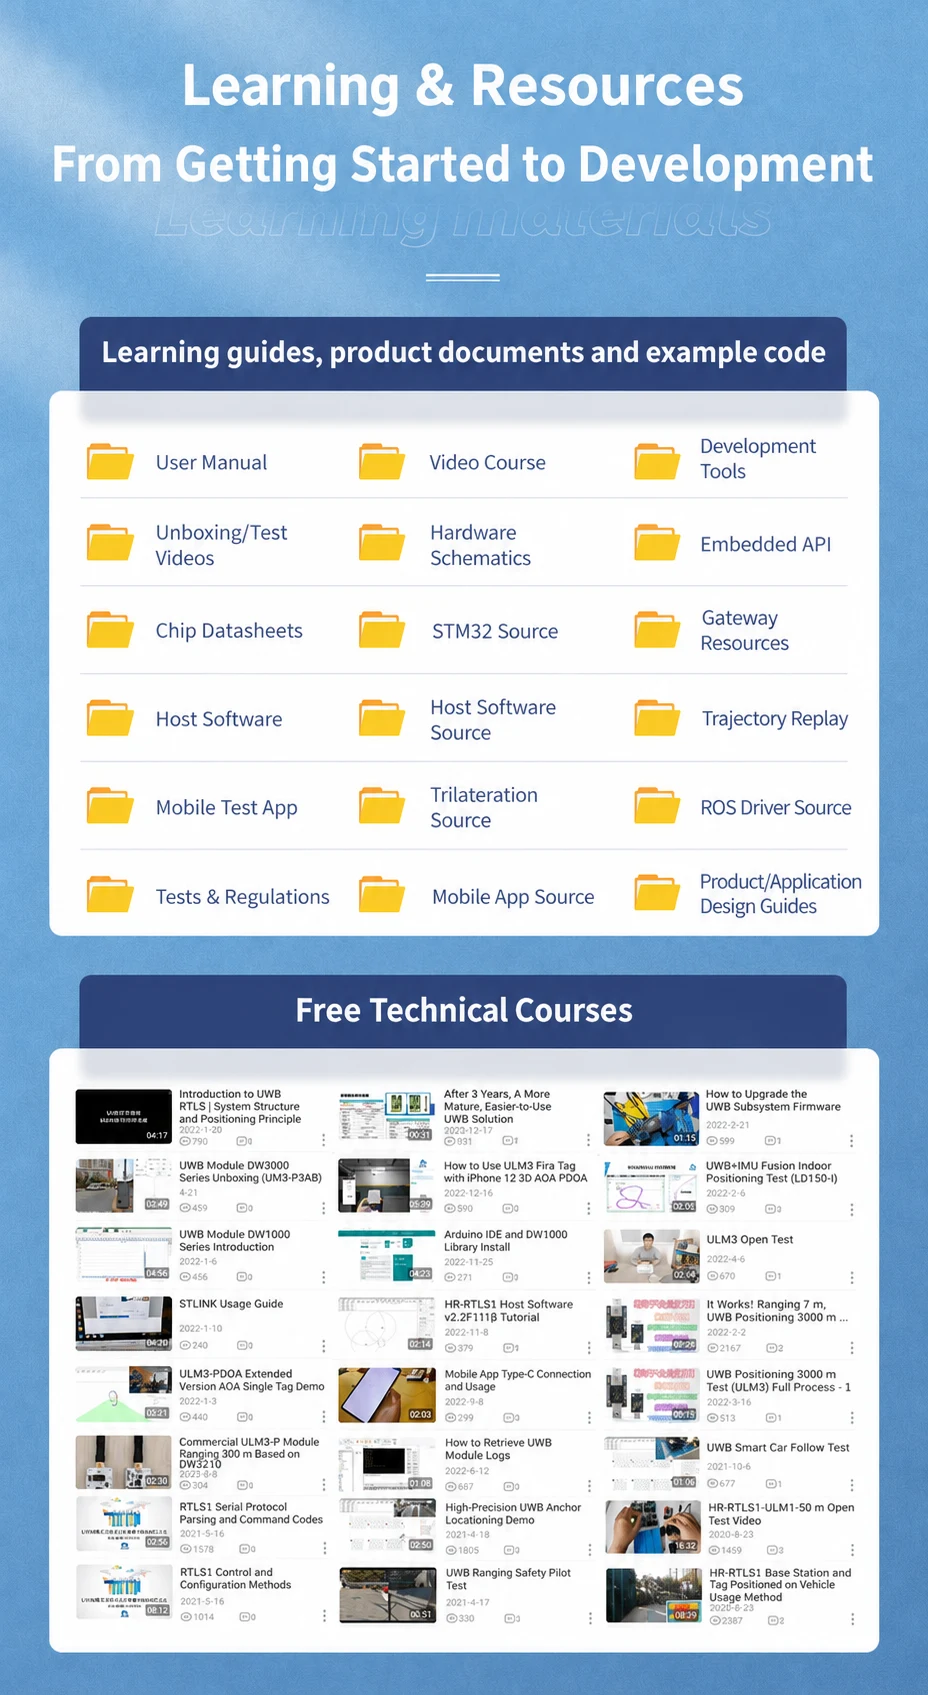
Read the manuals below, the robot following integration guide and the complete following kit page.
Detail
Product details
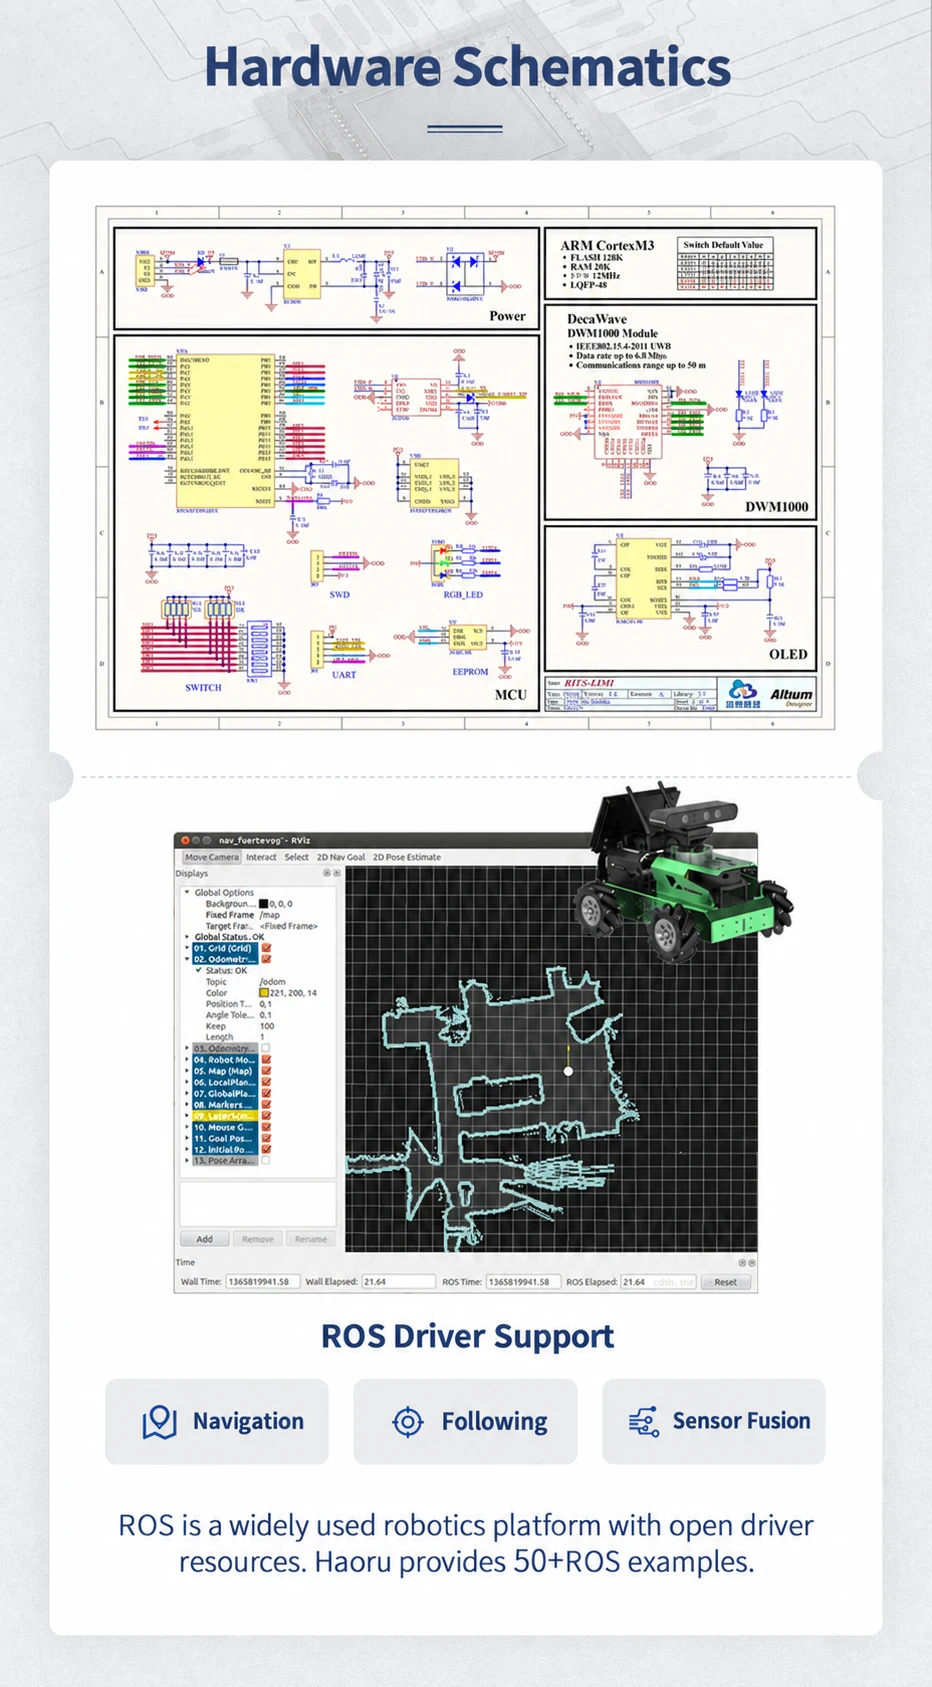
Downloads
Related resources
FAQ
FAQ
Can Haoru UWB positioning modules measure angles?
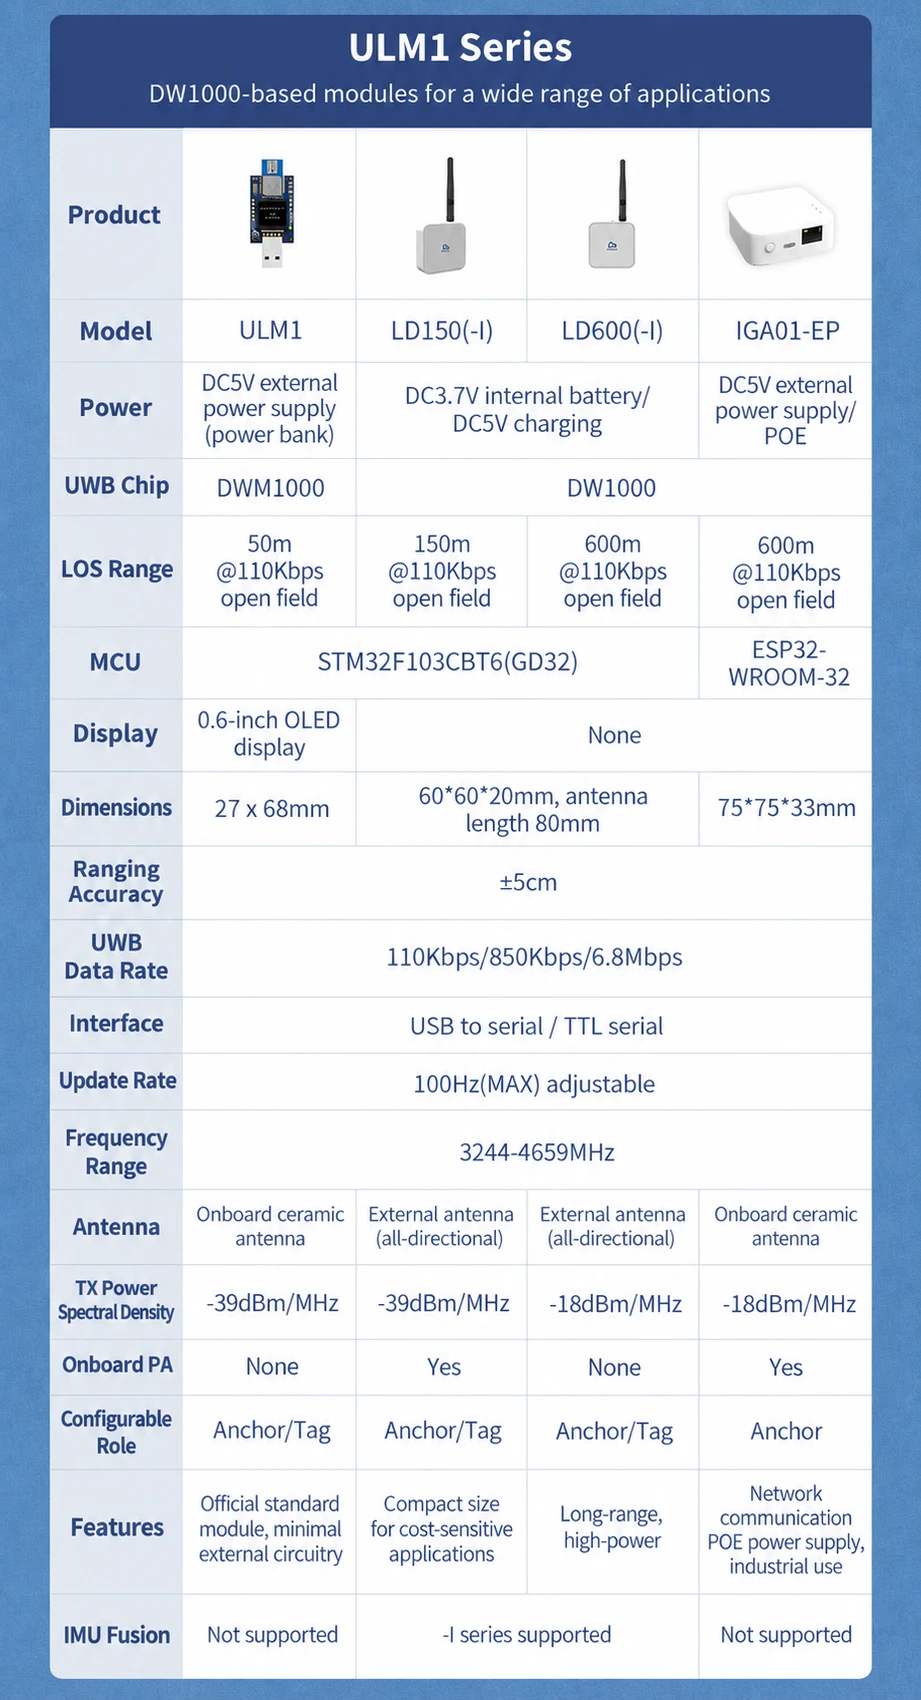
The Haoru ULM3-PDOA anchor measures angles over a ±60° range with ±5° accuracy. Standard tags such as ULM1 and ULM3 measure distance only and do not measure angles.
Do Haoru UWB modules need antenna calibration before use?
The source describes the modules as ready to use without user calibration. Check the applicable manual for factory calibration and any application-specific antenna-delay calibration requirements.
Is the Haoru UWB positioning system open source?
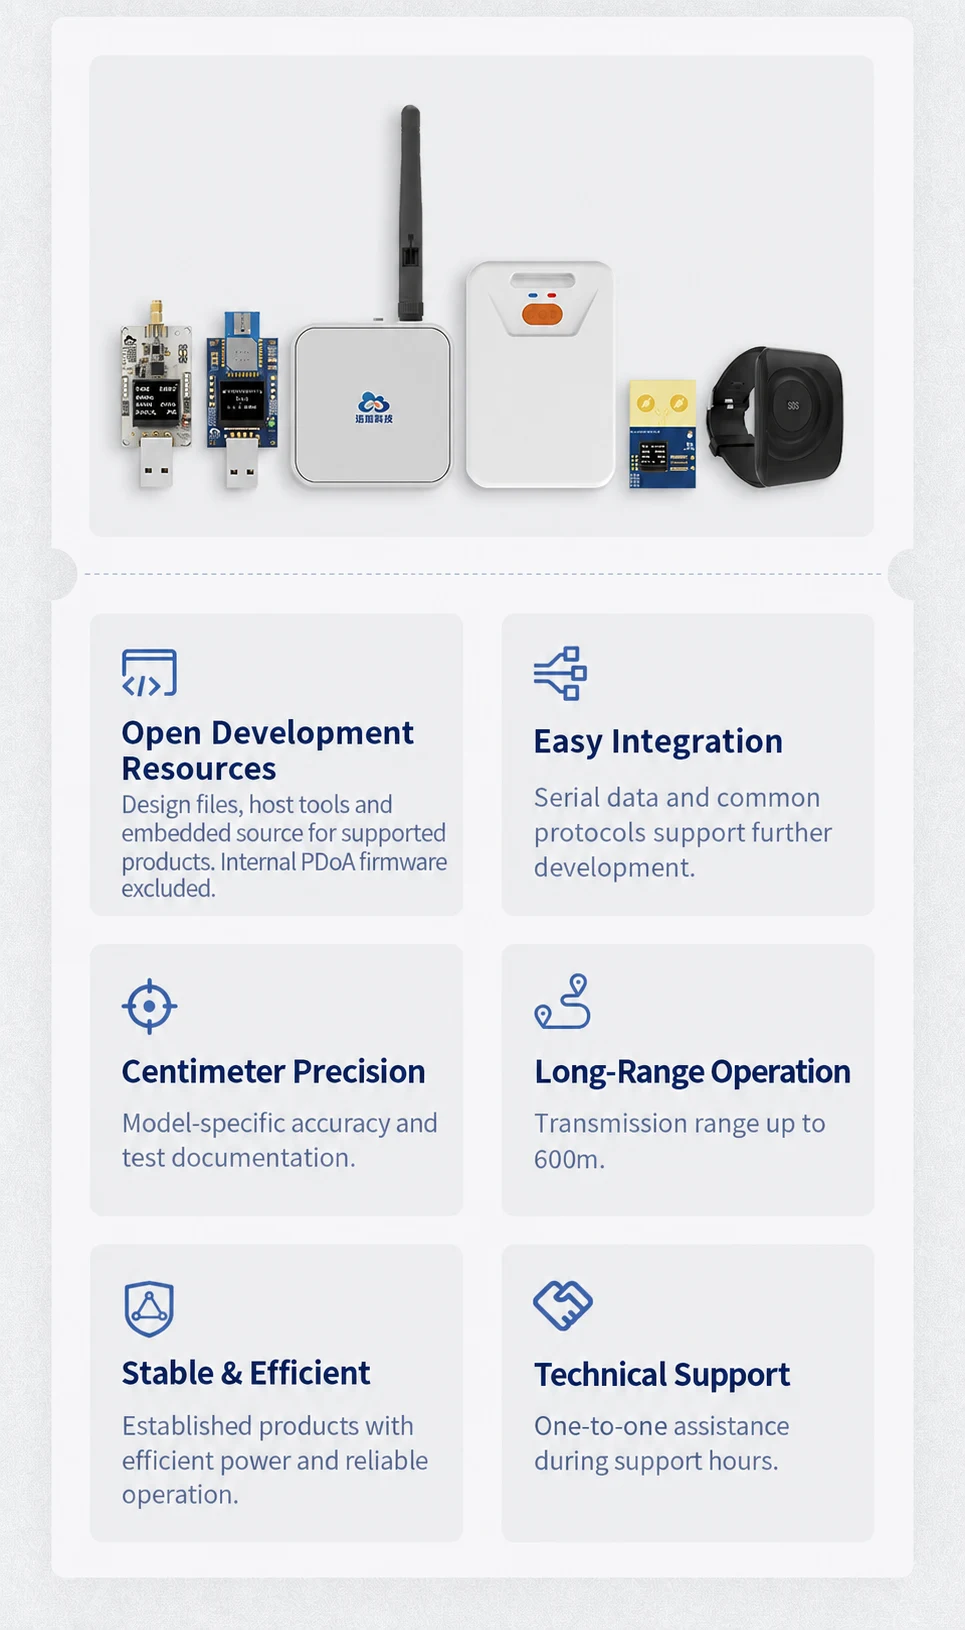
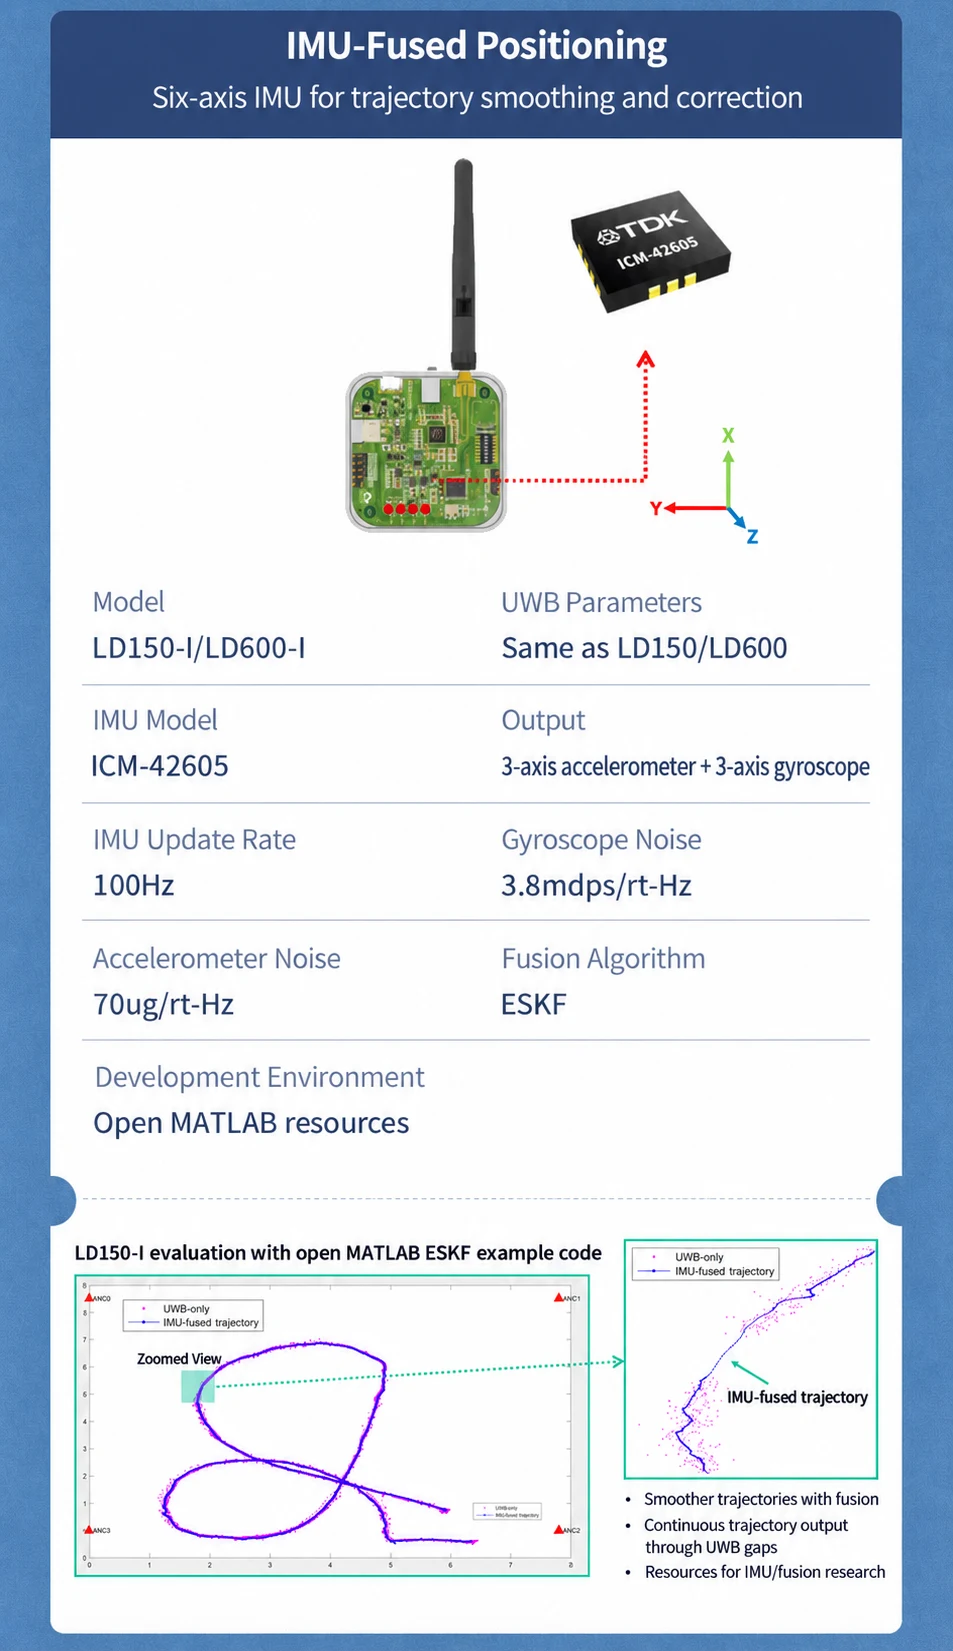
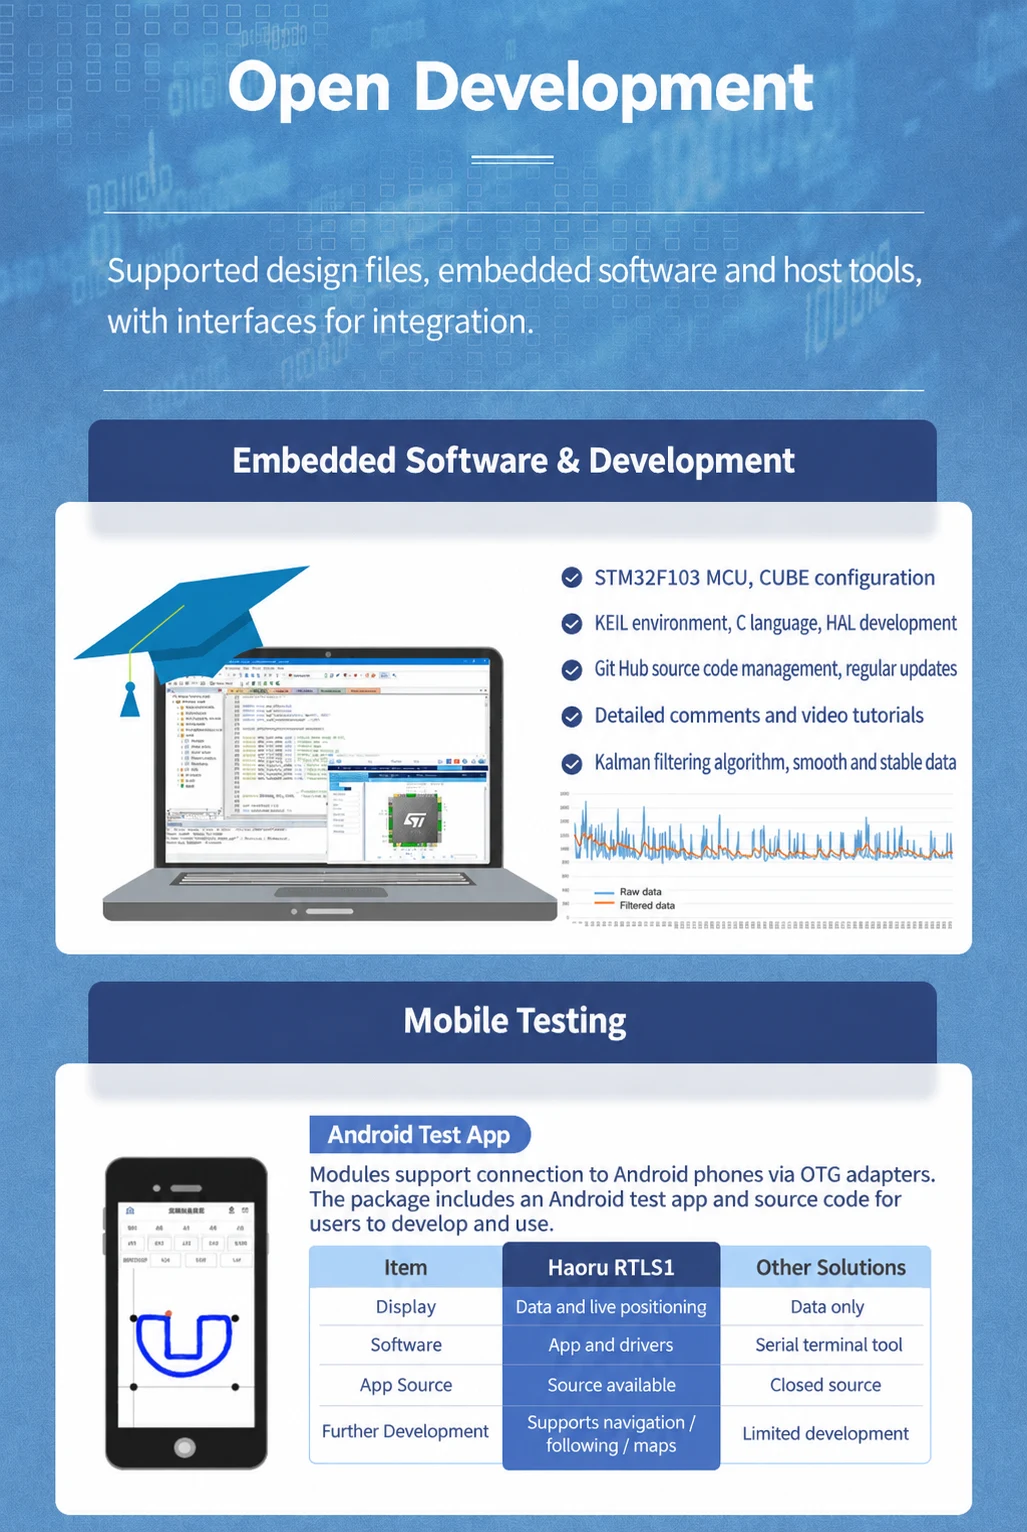
The source describes the Haoru UWB positioning system as fully open source, including embedded code, PC application code and algorithms. Development manuals and video tutorials are supplied to help customers learn and develop quickly. Confirm the licensing and available files for the specific product and firmware revision.
How can I display trajectories from UWB data? Is open-source software available?
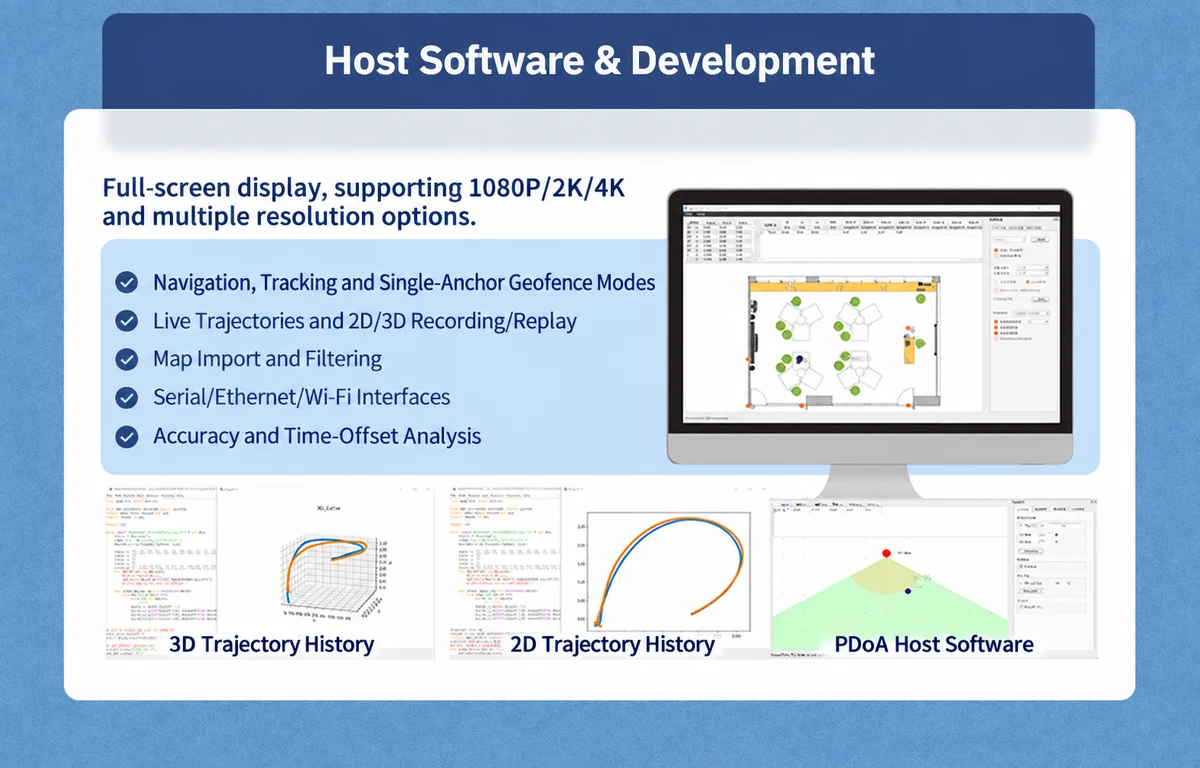
The source describes embedded code, PC application code and algorithms as open source, with development manuals and video tutorials. Confirm the supplied software and licensing for the selected product.
Which Haoru products can quickly form a positioning system?
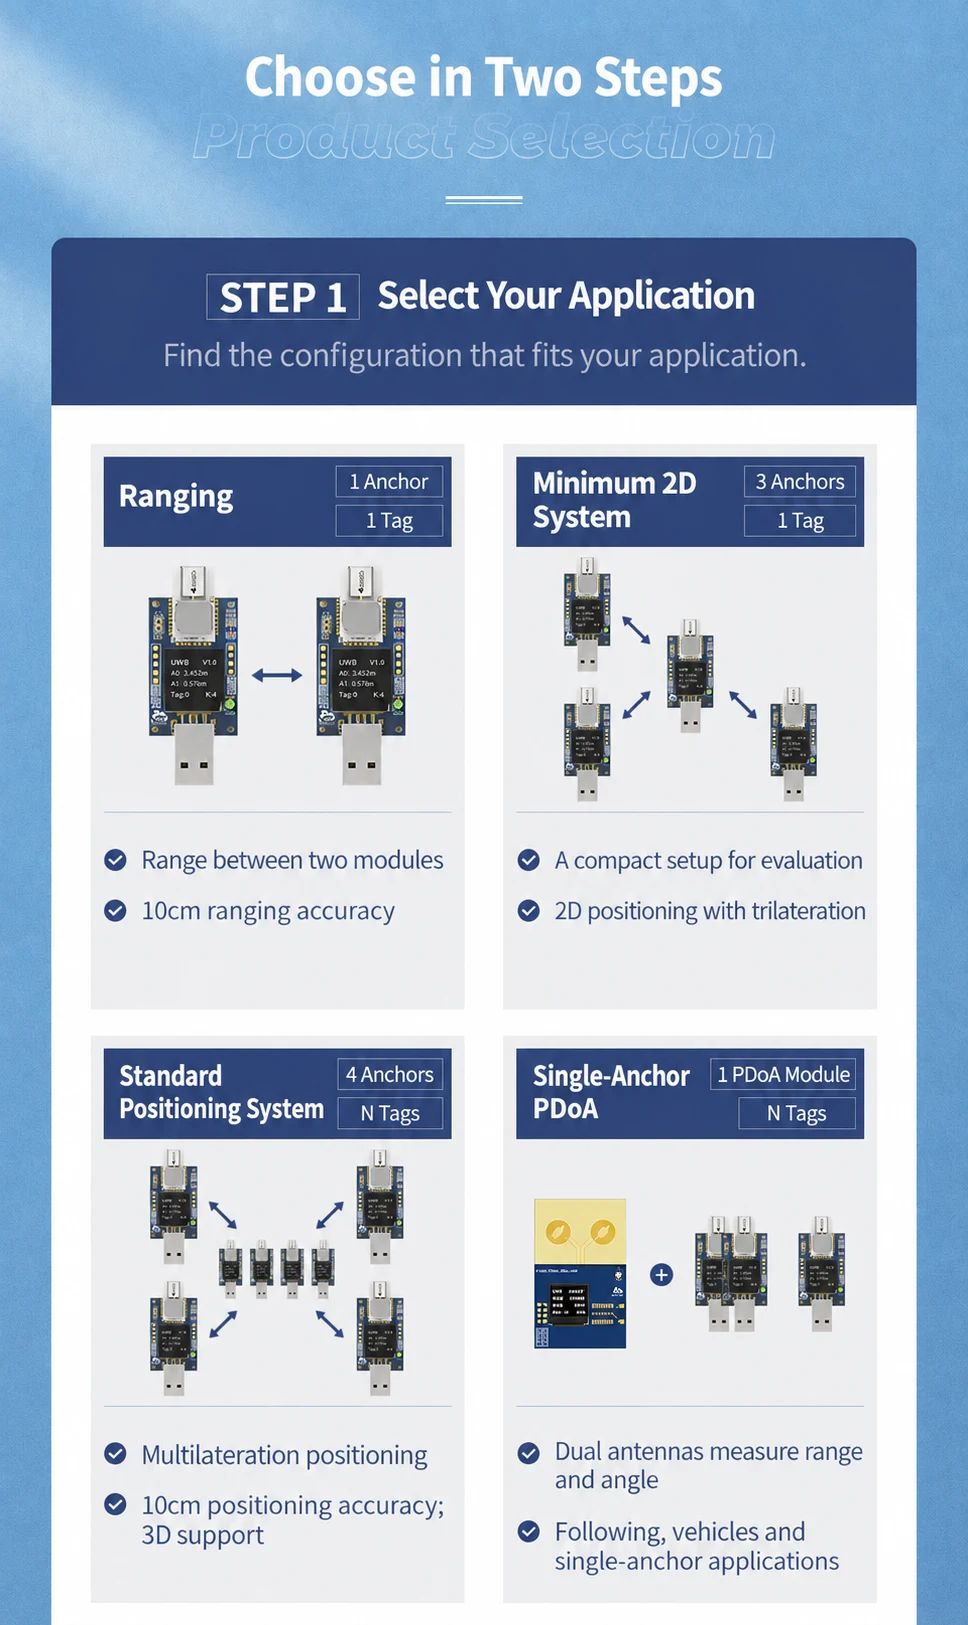
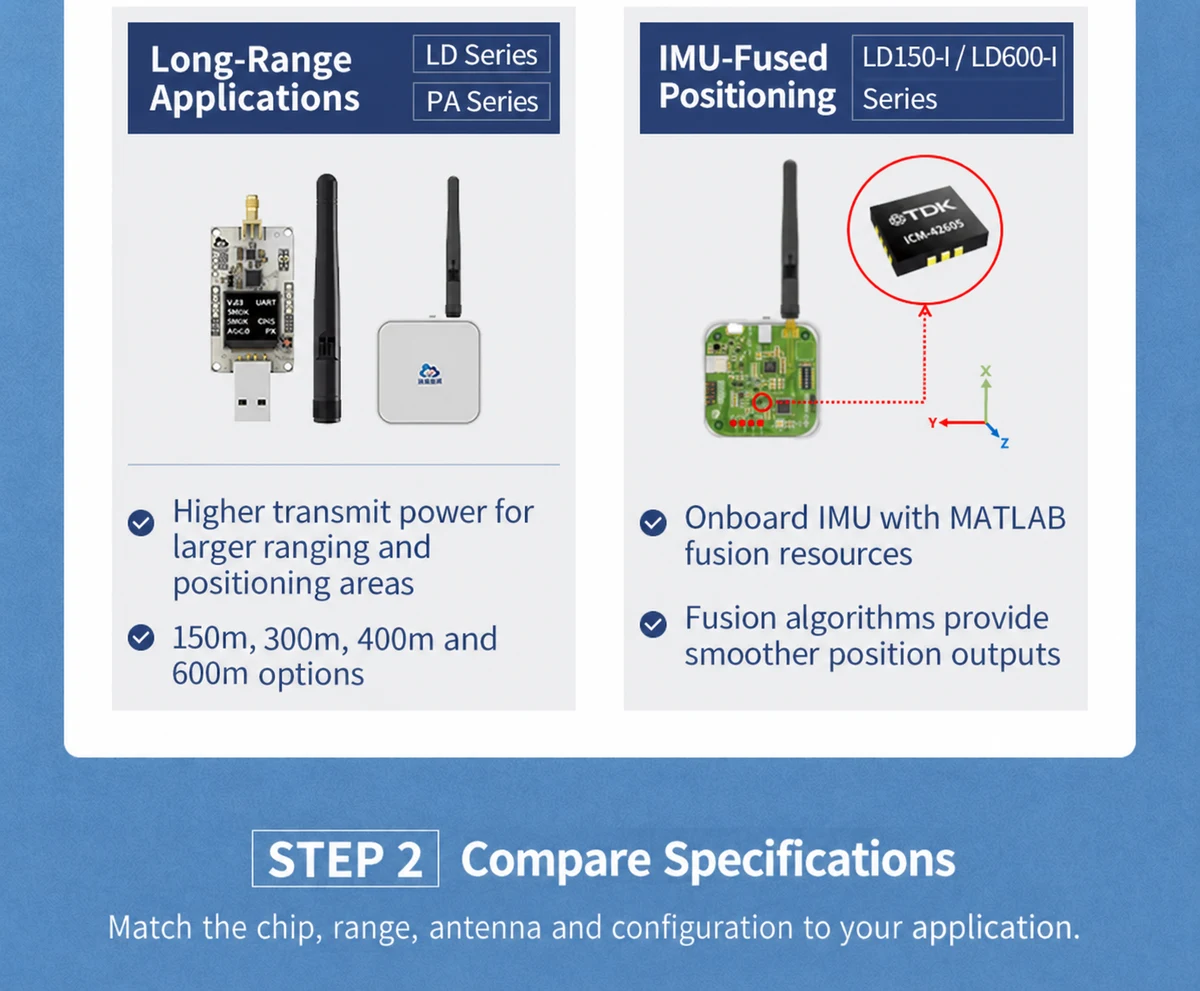
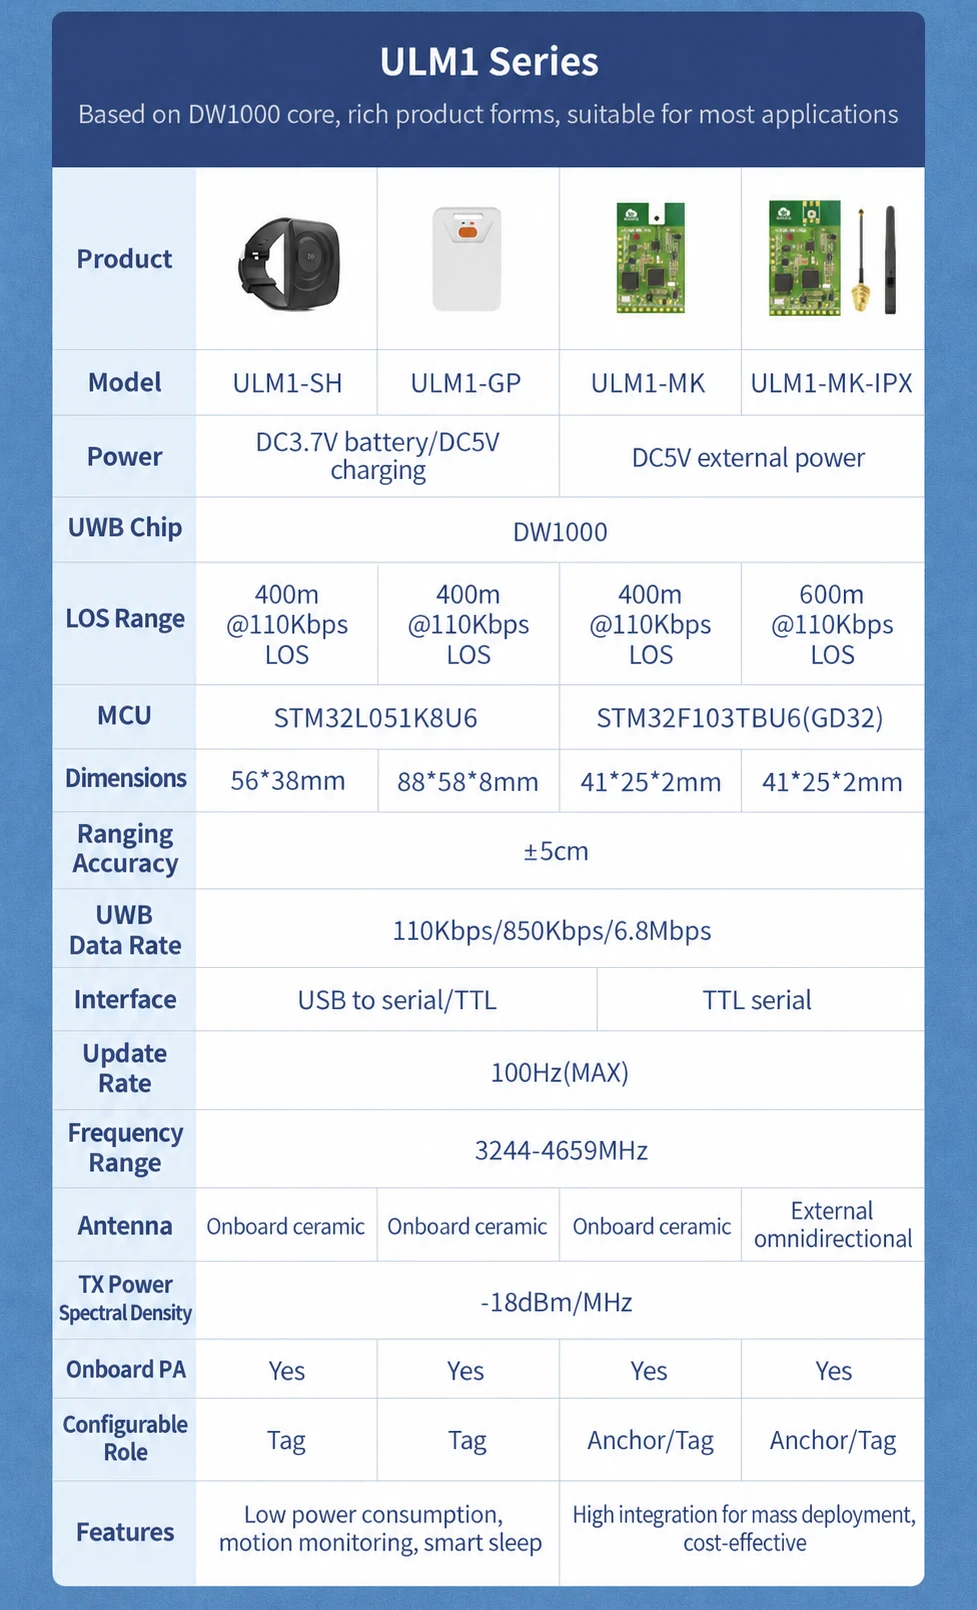
Haoru supplies modules and complete positioning solutions. Choose modules for product integration, or a complete system with anchors, tags and PC software for faster deployment. Select the configuration according to site size and indoor or outdoor use.
Why buy four anchors if three anchors can calculate a position?
1) Tags should operate inside the anchor coverage area. Four anchors can cover a rectangular area rather than a triangular one; the source describes an approximately doubled coverage area. 2) Wireless ranging can fail. With four anchors, a position can still be calculated when ranging to at least three succeeds; a three-anchor setup needs all three measurements to succeed. 3) A four-anchor, one-tag setup can be reconfigured as three anchors and two tags to learn multi-tag operation. 4) Four anchors can support 3D positioning when the installation spans length, width and height in a 1:1:1 arrangement.
PROJECT INQUIRY
Tell Us About Your Project
Share your application, accuracy, distance, quantity or payload requirements. The team responds during working hours, 09:00–18:00 China Standard Time, UTC+8.
Our team will use your contact details to respond to your project inquiry.