 Haoru UWB
Automatic Following Kits, Following Vehicles
Answer
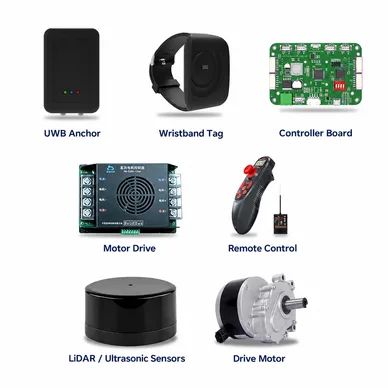
The system uses UART-TTL interfaces where specified, while wheel-control outputs are PWM. CH2 controls the left-wheel drive and CH3 the right-wheel drive, connected to the corresponding motor-controller inputs. Check the wiring diagram for the specific controller.